IMU Overview
This module demonstrates motion sensing using the Renesas DA14531 Pro Development Kit and the STMicroelectronics LSM6DSOX 6-DOF IMU module.
The example is designed for the KuoQuo Pivot smart ring proof-of-concept platform and provides:
- IMU initialization
- Accelerometer and gyroscope data reading
- FIFO support
- Motion data streaming
- Optional BLE GATT service integration
The same hardware setup supports two firmware variants:
| Firmware Variant | Description |
|---|---|
| Basic | Simple IMU communication and sensor validation |
| Basic + BLE | IMU data streaming over Bluetooth LE |
Prerequisites
Before starting this example, it is recommended that you have successfully completed the Renesas DA14531 Blinky example from the SmartBond SDK6 examples.
This ensures:
- SDK environment is properly configured
- Keil setup is working correctly
- Flashing and debugging are functional
- UART and GPIO configuration are verified
DA14531 Blinky Peripheral Example (Renesas Official Guide)
Getting Started
Requirements
Hardware
Info
This tutorial explicitly utilizes the DA14531 Pro Development Kit. However, you can also use the DA14531 USB Development Kit—just be sure to adjust your pin configurations and jumper settings accordingly.
- DA14531 development board
- LSM6DSOX IMU module
- Jumper wires
Software
- Keil uVision
- DA14531 SDK6
- J-Link or UART flashing tool
Hardware Preparation
The LSM6DSOX (Slave) is connected to the DA14531 Pro Development Kit (Master) using SPI mode.
Wiring Diagram
Note
- J1 and J2 are general-purpose breakout headers from the DA14531 Pro Development Kit.
- GPIO references in this guide correspond to pins exposed through these headers.
- Wire colors are recommendations only and can be changed as needed.
- SPI mode is used for this example.
- INT1 is optional but recommended for interrupt/FIFO-based applications.
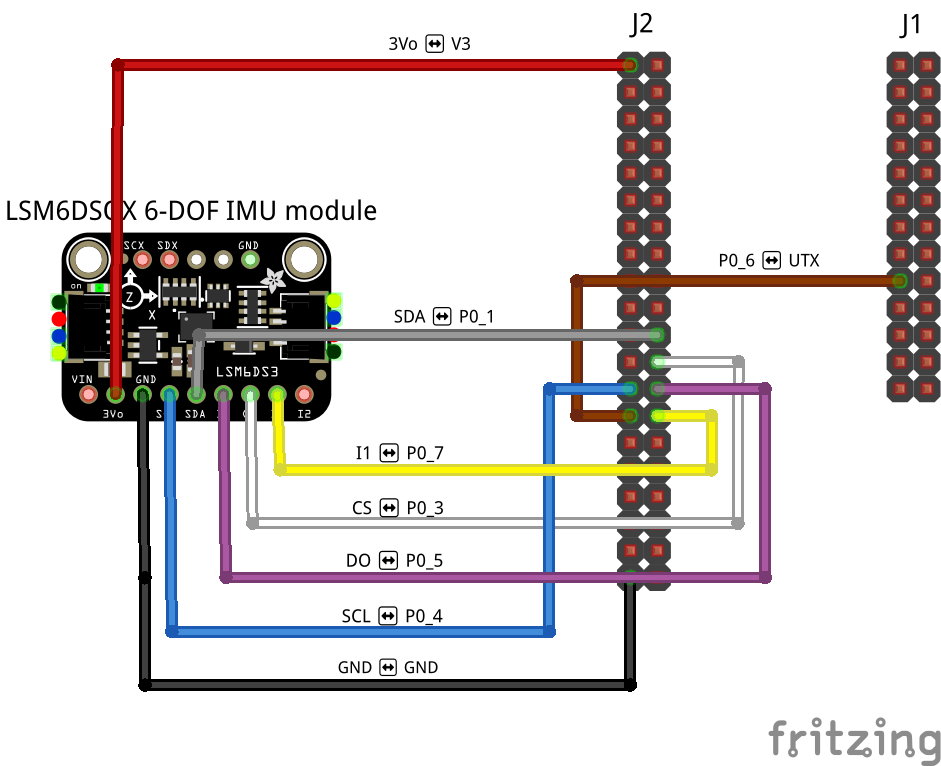
Pin Connections
| LSM6DSOX Pin | DA14531 Pin | Function | Wire Color |
|---|---|---|---|
| 3Vo | V3 | Power (3.3v or 1.8v) | Red |
| GND | GND | Ground | Black |
| SCL | GPIO0_4 (SPI_CLK) | SPI Clock | Blue |
| SDA | GPIO0_1 (SPI_DO) | SPI MOSI | Grey |
| DO | GPIO0_5 (SPI_DI) | SPI MISO | Purple |
| CS | GPIO0_3 (SPI_CS) | Chip Select | White |
| I1 (INT1) | GPIO0_7 | Interrupt | Yellow |
| - | GPIO0_6 | UART TX Debug | Brown |
IMU Basic
Simple hardware validation and IMU communication testing.
Features
- SPI communication
- WHO_AM_I verification
- Accelerometer reading
- Gyroscope reading
- UART debug logs
Intended Use
- Sensor bring-up
- Hardware debugging
- Driver development
IMU Basic + BLE
This section is currently under development.
We’re actively working on it and will have updates available soon. Thank you for your patience!